
Robotic autonomy · Last-hundred-feet delivery
Autonomous Drone Delivery to Door
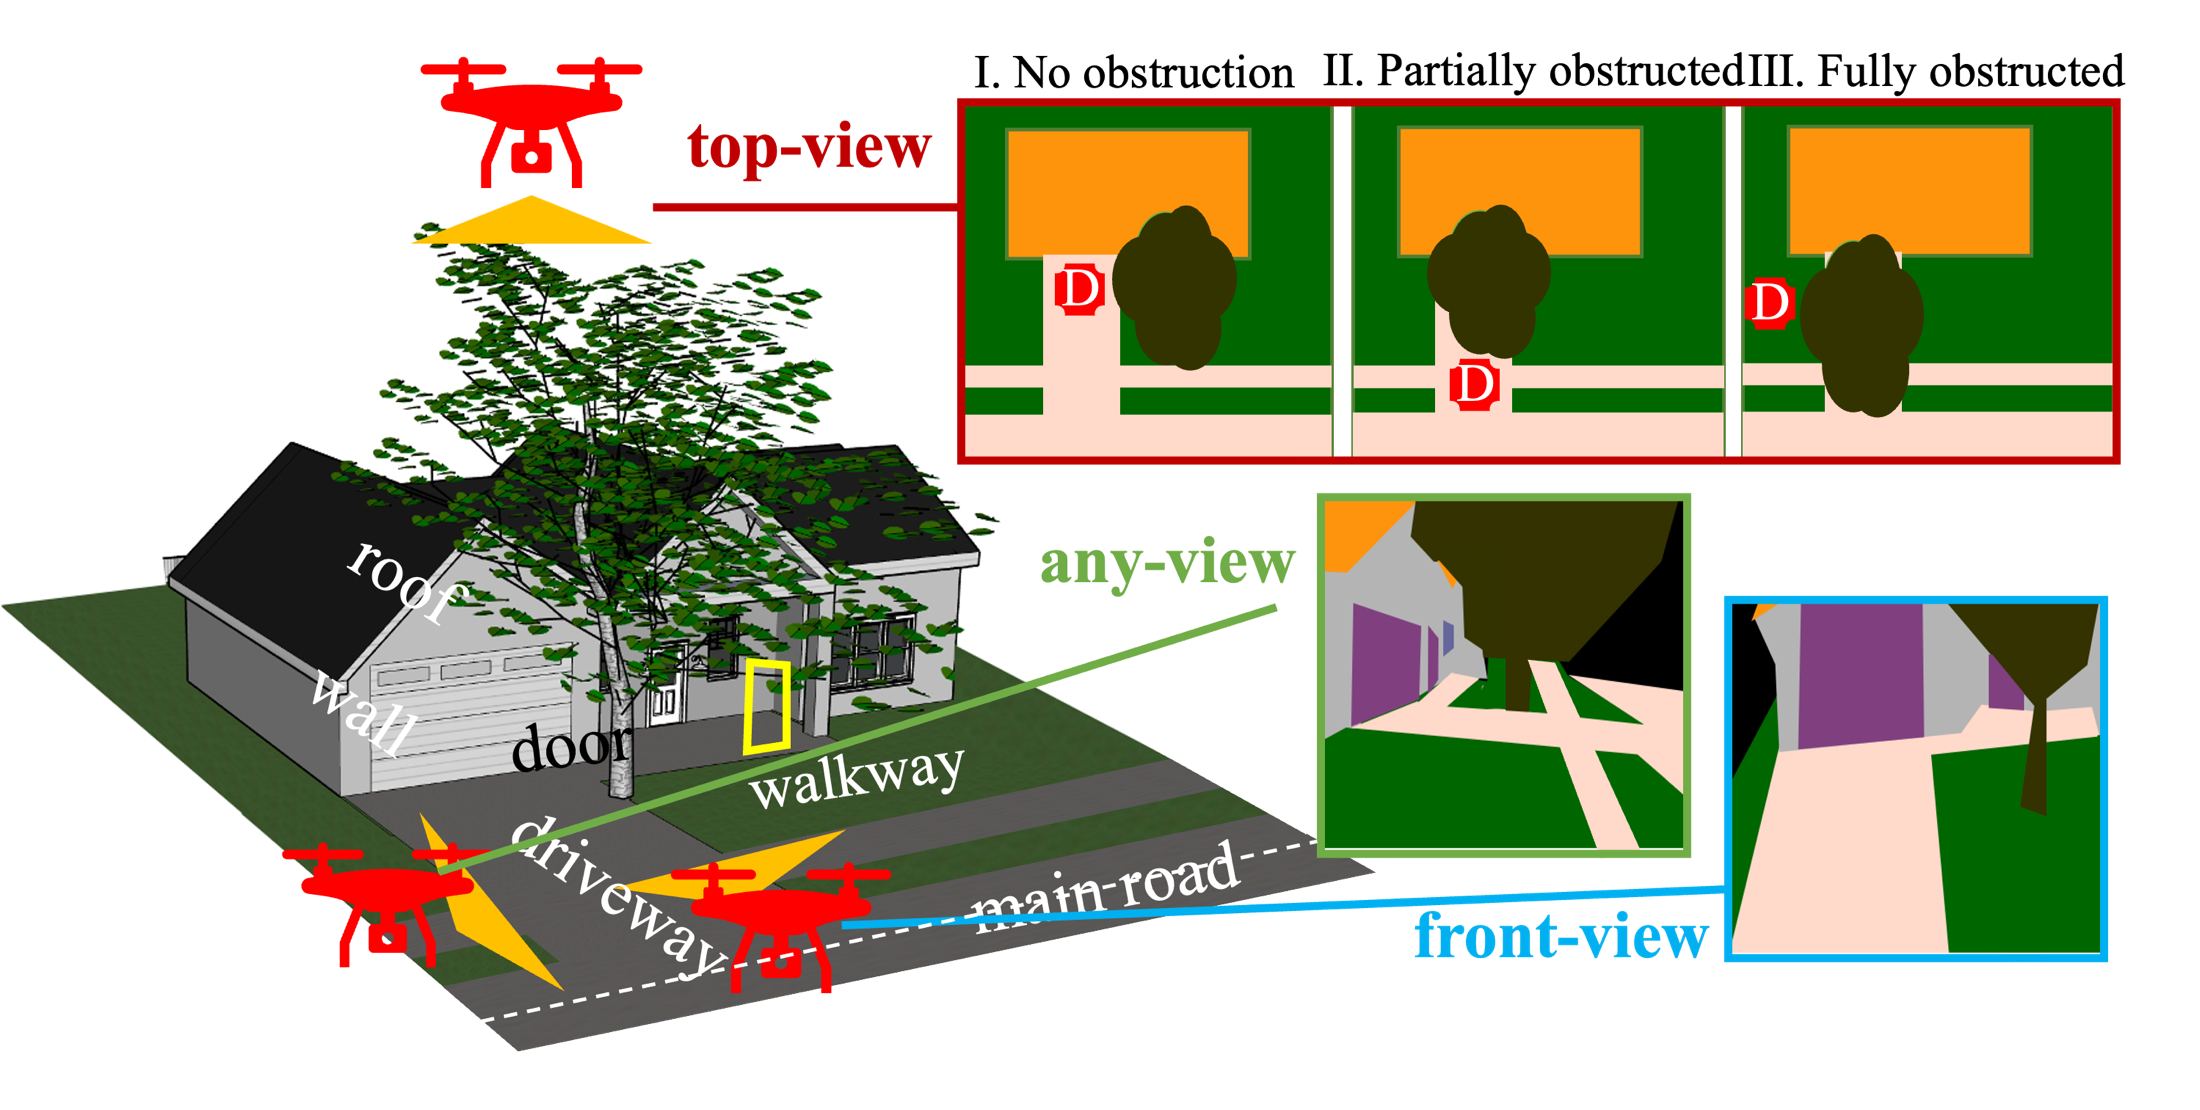
This project addresses the last-hundred-feet problem in autonomous drone delivery: moving from a broad destination to a practical drop-off point near a home's front or garage door.
01 / Research frame
The problem
The door may be invisible from an initial top-down view, and visual conditions change across viewpoint, season, weather, illumination, and time of day. A useful system must reason about stable house structure while the drone approaches.
The approach
Structural Semantic Segmentation (SSS) uses house-aware semantics to guide progressive approach. Robust Structural Semantic Segmentation (RSSS) extends that idea by using stable structure and spatial layout to improve results under changing environmental conditions.
Contributors
- Shengqing Xia
- Jiaxin Du
- Junpeng Guo
- Chen Peng
- Chunyi Peng
03 / Associated work
Associated publications
RSSS: Robust Structural Semantic Segmentation for Autonomous Drone Delivery to Door
Shengqing Xia, Jiaxin Du, Chunyi Peng · IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
SSS: Towards Autonomous Drone Delivery to Your Door Over House-Aware Semantics
Shengqing Xia, Junpeng Guo, Chunyi Peng · 25th International Workshop on Mobile Computing Systems and Applications (ACM HotMobile)
Demo: Towards Autonomous Drone Delivery to Your Door Over House-Aware Semantics
Shengqing Xia, Junpeng Guo, Chen Peng, Chunyi Peng · 25th International Workshop on Mobile Computing Systems and Applications (ACM HotMobile)